
Verification, hand soldering, testing, firmware calibration, robot integration
Supercap Controller Board (STM32)
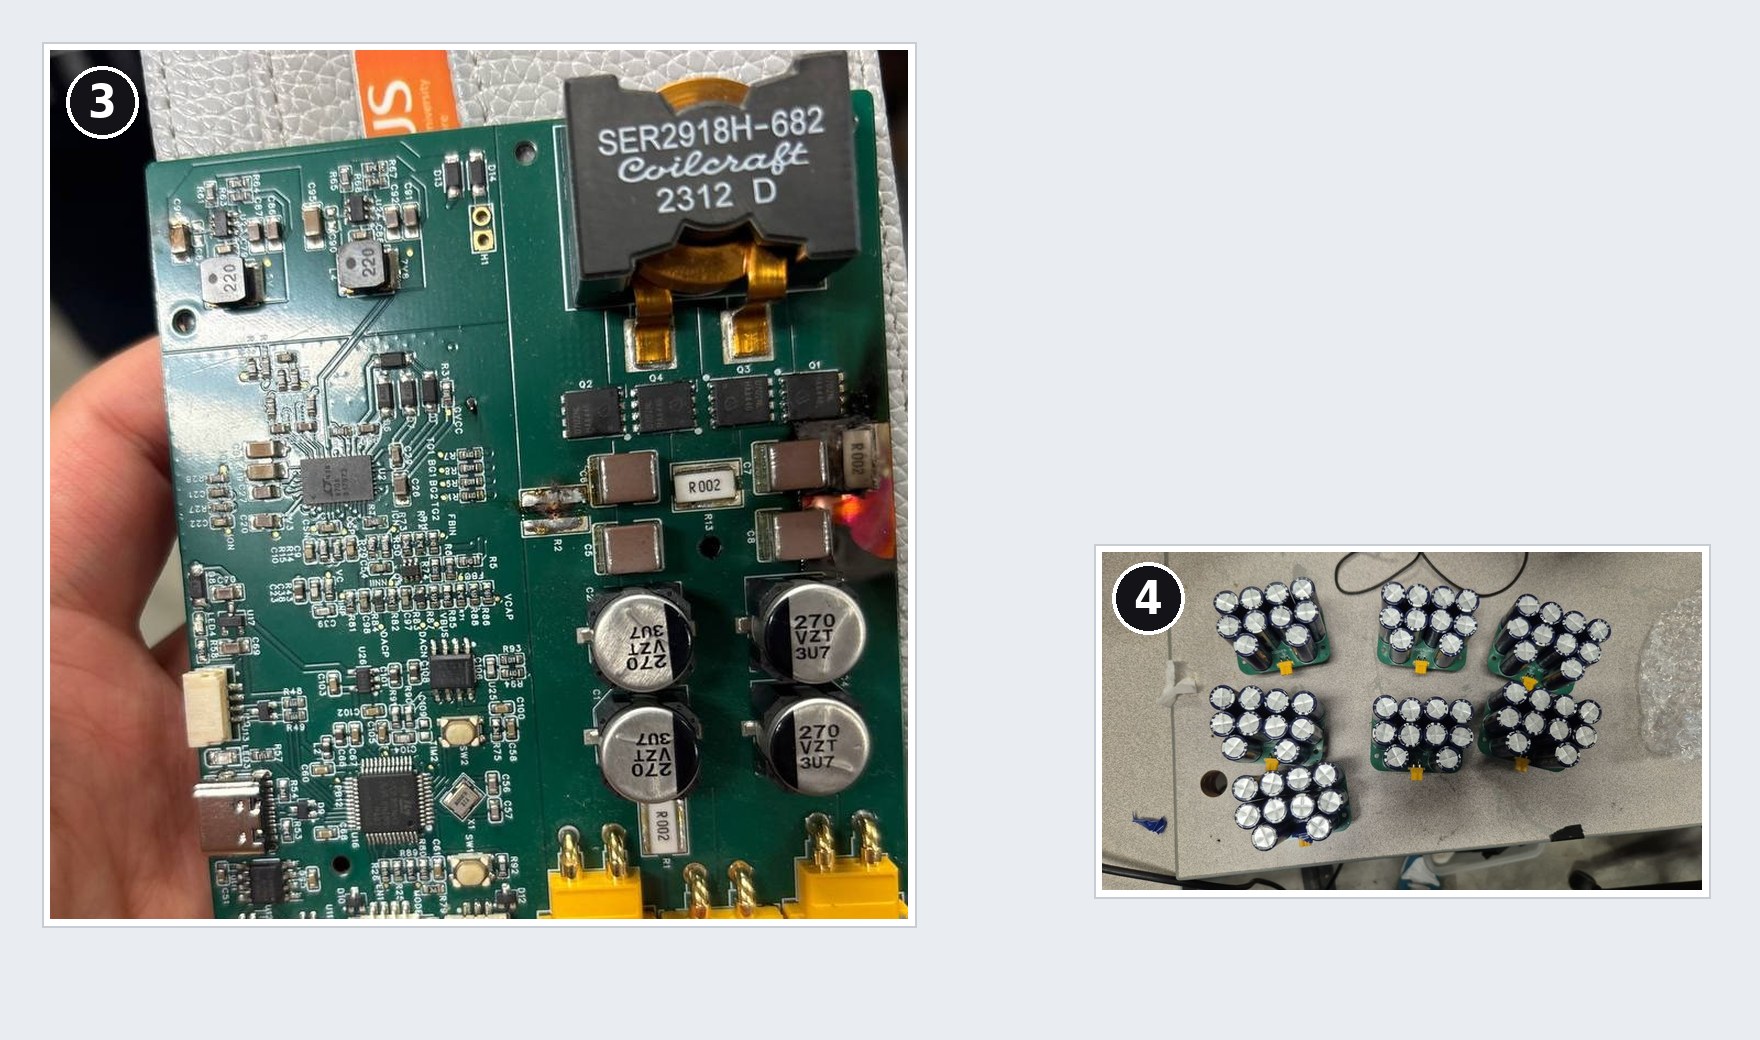
Verified, hand-soldered, tested and integrated a senior-designed STM32 supercap controller for the Calibur robot.
Overview
- PCB designed by a senior on the team; I took it from design to a working part
- Verified and validated the design in EasyEDA (schematic and PCB review)
- Hand-soldered the SMD parts on a hot plate
- Tested the board with the supercap banks we built for testing
- Calibrated the firmware on the STM32
- Integrated the controller into my robot
- Studied the bidirectional buck-boost power stage
Highlights
- PCB designed by a senior on the team; I took it from design to a working part
- Verified and validated the design in EasyEDA (schematic and PCB review)
- Hand-soldered the SMD parts on a hot plate
- Tested the board with the supercap banks we built for testing
- Calibrated the firmware on the STM32
- Integrated the controller into my robot
- Studied the bidirectional buck-boost power stage